Vision-Language-Action Models for pHRI
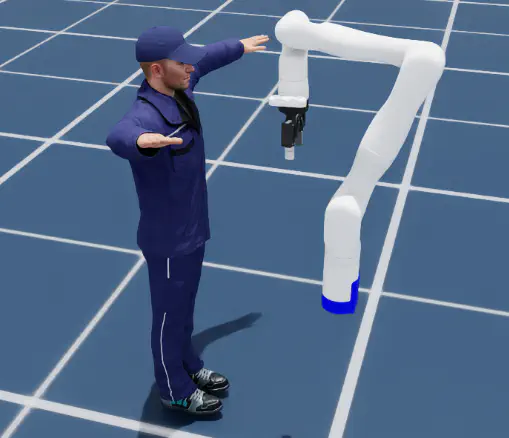
Vision-Language-Action (VLA) models are power tools in robotics, but they are not trained for physical human-robot interaction. Here, we explore different methods for allowing VLAs to be safely used with humans. The first step is to develop a sim-to-real pipeline for collecting pHRI demonstrations.
You may find the paper on ResearchGate: https://www.researchgate.net/publication/414405124_From_Simulation_to_Human_Contact_Sim-to-Real_Tuning_of_Vision-Language-Action_Models_for_Physical_Human_Support_Motions

Abdallah Hassan
PhD Student (2026)
My research focuses on generlaizing robotics to a variety of tasks including iteracting with humans.